RESEARCH / AGENT-DRIVEN INTERACTION
GPT 驱动的
人物与家具
交互建模
以已有骨架人物和家具为输入,GPT 根据场景数据与图像生成姿态编辑脚本,通过 MCP 调用 Blender,并结合变形网格评估与多视角观察迭代调整。
查看系统执行流程 ↓WHO DECIDES / WHO EXECUTES
AI 决策与
Blender 执行架构
Codex 管理模型与工具调用循环,Interaction MCP 提供任务接口、状态校验与评估反馈,社区 Blender MCP 将 Python 脚本提交至 Blender 执行。
BLENDER → GPT
场景与骨架状态采集
通过 MCP 查询场景对象、控制骨、IK 和约束,向 GPT 返回世界坐标下的关节状态与多视角图像。
scene_snapshot / observe_poserig: "Human.rig" bones: 160 images: [world −Y, +X, +Z] coordinates: world metres
点击步骤或导航按钮查看对应环节。示例数值取自 test3 首次编辑记录;本页为实验记录展示。
THE PRACTICAL ENTRY POINT
interaction-mcp run --config …系统基于输入资产建立独立工作场景,每次修改前保存检查点,并校验骨长、绑定、人体拓扑与家具完整性。
REAL PRACTICE / TEST3
六轮坐姿迭代
与几何反馈
test3 记录了六轮自由 Python 姿态编辑及对应视图、脚本和几何指标。后续单参数微调作为独立接口完成回归验证,两组实验资料分别展示。
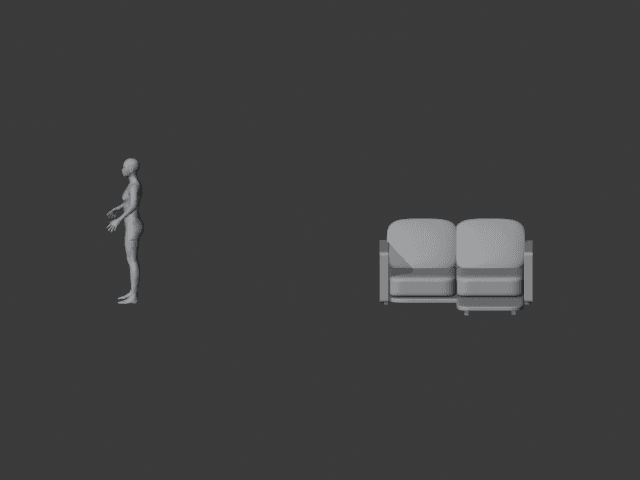
INITIAL OBSERVATION / TOOL STEP 02
初始场景与骨架状态
MCP 返回输入人物、家具、骨架数据和世界轴三视图。Luna 查询表面与关节状态,确定朝向后生成首次坐姿编辑脚本。
全局朝向与初始坐姿设置
依据当前图像与几何评估制定后续操作。相机名称对应世界轴方向。家具开口方向需结合几何与图像识别;本次实验判定为 +X,图像保留原始取景。
COLLISION AND SELF-INTERSECTION TRADEOFF
碰撞与自交指标的迭代变化
第二次编辑后,家具重叠降至 168.88 cm³,新增人体自交升至 490 对。两项指标及对应场景均被记录,供 Luna 分析后续修正方向。
RIG → DEFORMATION → GEOMETRY
骨架控制与
蒙皮响应测量
单一控制输入可经约束与蒙皮驱动多个关联关节和表面点。系统分别记录请求增量、控制器响应与采样皮肤位移,并以变形网格评估碰撞。
世界坐标增量输入
root / WORLD Z / +5 mm→骨骼通道坐标转换
convert_local_to_pose→FK / IK 与约束求解
view_layer.update()→变形网格采集
evaluated_get → to_mesh→WORLD-TO-CHANNEL COORDINATE TRANSFORM
世界坐标增量转换后的原生 location 通道分量:
原生通道分量由坐标基与父级变换共同决定;世界 Z 位移对应单一输入标量,需经坐标转换写入骨骼通道。
EVALUATED MOTION RESPONSE
控制量经骨架求解和蒙皮变形作用于表面,碰撞评估使用最终变形网格。骨骼与皮肤的响应通过实际测量建立对应关系。
本轮位移统计覆盖 74 个皮肤采样点,最大值仅适用于该采样集合;接触与穿模检测使用实际变形网格。
FINE ADJUSTMENT / COMPARE BEFORE RETAINING
统一基线下的
单参数候选比较
整体姿态形成后,微调阶段每次调整一个控制量。围绕估计值构建 3 或 5 个独立候选,使用固定相机和几何指标比较输入增量与实际响应。
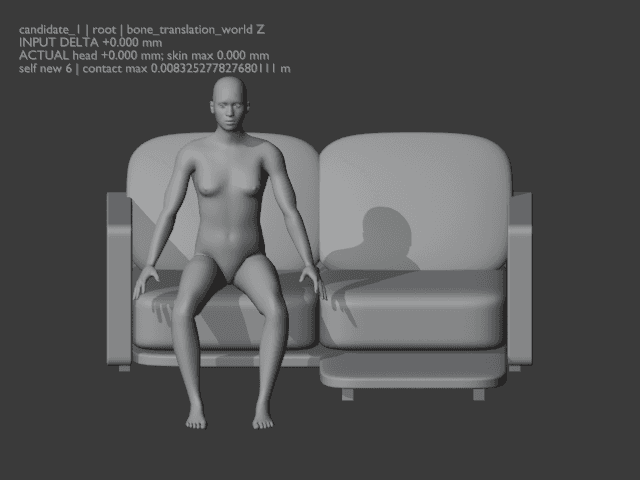
CONTROL INPUT / DEFORMATION RESPONSE
保持 0 mm
- 控制器实际位移
- 0.000000 mm
- 皮肤采样最大位移
- 0.000 mm
- 家具重叠
- 0.000 cm³
- 新增自交
- 6 对
- 最大接触见证间隙
- 8.325 mm
+5 mm 候选将新增自交由 6 对降至 4 对,同时增大臀部与坐垫间隙。候选选择需综合几何指标、接触条件与视觉评估。
此图为候选工具调用生成的原始 PNG。 本批由离线回归脚本固定选择 +5 mm,模型调用为 0 次;网页交互用于浏览已保存的候选资料。
STAGE 01
保存已确认的 working.blend 和独立检查点,作为所有候选的共同起点。
save → checkpoint查看这个候选批次的真实参数 +
{
  "parameter": {
    "bone": "root",
    "kind": "bone_translation_world",
    "axis": "Z"
  },
  "deltas": [
    -0.005,
    0,
    0.005
  ],
  "comparison_view": "side"
}RESULTS / LIMITS / REPRODUCIBLE EVIDENCE
实验结果、验收状态
与执行记录
分别汇总 AI 坐姿实验与后续接口回归,记录最终场景、几何验收状态、剩余问题及逐步执行资料,支持结果复核与故障追溯。
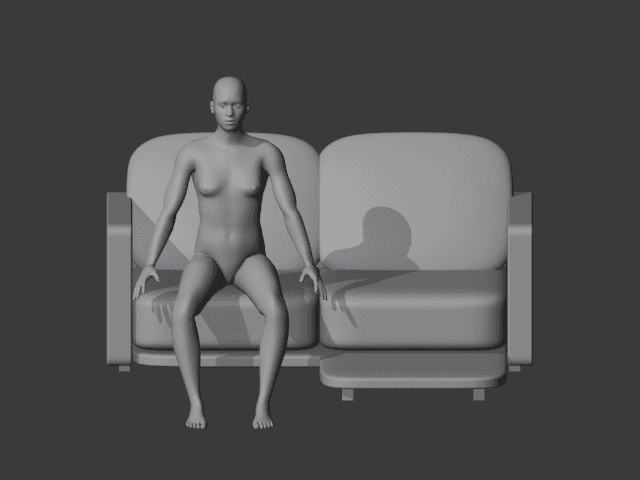
TEST3 / ACTUAL AGENT RESULT
坐姿目标达到,
几何验收未通过。
人物面向沙发 +X 开口,臀部与双脚支撑见证点满足检测条件。Luna 记录剩余人体自交,系统将场景保存为 draft.blend。
- 人物 / 家具重叠
- 0 cm³
- 朝向水平误差
- 0°
- 新增人体自交
- 6 对
- 原始 / 当前自交
- 32 / 38
- 意图达到 / 几何验收
- 是 / 未通过
剩余自交分布于髋部和右膝。局部蒙皮变形可能参与其形成,具体成因尚待验证;当前结果按几何验收未通过记录。
AI EXPERIMENT / 2026.10.14
6 次编辑test3:GPT-6 Luna 经 Codex、MCP 自主查询和执行 Python。87 条工具记录可追踪。
OFFLINE REFINEMENT REGRESSION
6 → 4 自交坐姿副本的 +5 mm 候选将新增自交由 6 对降至 4 对,结果仍为草稿;该批候选由离线脚本选择。
INTERFACE VALIDATION
72 项通过覆盖候选复用、恢复、无响应、停滞、保持条件与故障。本轮优化验证的模型调用为 0。
A REAL REJECTED CANDIDATE / SYNTHETIC TEST
候选应用的保持条件校验
合成场景将接触间隙上限设为 30 mm。+2° 候选超出限制被拒绝,+1° 候选满足该保持条件;程序执行约束校验,最终选值由调用方决定。
无响应诊断
请求值与实际响应分别报告,无响应候选不能当作有效位移保留。
最佳姿态恢复
AI 可保存认可的最佳姿态;新预览不废弃相同基线的旧候选。
停滞检测与重规划
无进展或往复时,先恢复最佳姿态,再受控返回整体调整。预算不重置。
执行不确定性处理
通信或超时没有可靠确认时冻结,不自动重放。保留最后确认的模型和日志。
展开全部 87 次真实工具记录:查询、看图、决策、编辑与验收 +
按真实日志顺序排列。时间为日志文件完成时间;调用完成不等于姿态验收通过。此处展示实际参数和精简反馈,图像链接指向那次调用产生的原图。
001scene_snapshotv0 → v0完成
2026-10-14 / 06:47:05.449202+08:00
{
  "bone_query": "",
  "offset": 0,
  "limit": 120,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 160,
"next_offset": 120,
"revision": 0
}002observe_posev0 → v0完成
2026-10-14 / 06:47:09.327199+08:00
{}{
"revision": 0
}003observe_posev0 → v0完成
2026-10-14 / 06:47:19.031303+08:00
{}{
"revision": 0
}004declare_orientationv0 → v1完成
2026-10-14 / 06:47:29.451650+08:00
{
  "body_forward_local": [
    0,
    -1,
    0
  ],
  "furniture_opening_world": [
    1,
    0,
    0
  ],
  "target_forward_world": [
    1,
    0,
    0
  ],
  "evidence": "The world_minus_Y camera is at (0.763,-12.381,3.003), image-right +X and image-up mostly +Z; it shows the character's face/chest, so the rig's default local -Y is forward. The world_plus_X camera is at (15.252,2.107,3.003), image-right +Y, and shows both sofa seat cushions from their open side. The world_top image has right=+X/up=+Y: the sofa back is along its -X edge, seats extend toward +X, with the chaise projecting farther +X. Sofa bounds are X .398..2.053 and Y 2.791..4.549. Therefore the sofa opening and intended seated facing are +X.",
  "reference_bone": "spine03"
}{
"revision": 1,
"declared": true
}005declare_orientationv1 → v2完成
2026-10-14 / 06:47:35.094594+08:00
{
  "body_forward_local": [
    0,
    -1,
    0
  ],
  "furniture_opening_world": [
    1,
    0,
    0
  ],
  "target_forward_world": [
    1,
    0,
    0
  ],
  "evidence": "The world_minus_Y camera position is (0.763,-12.381,3.003), with image-right +X and image-up mostly +Z; it shows the character's face/chest, so rig-local -Y is the current forward. The world_plus_X camera at (15.252,2.107,3.003), with image-right +Y, shows both sofa seat cushions from their open side. The top camera has right=+X/up=+Y: the sofa back lies on its -X edge and its seats/chaise extend toward +X. Sofa bounds are X .398..2.053 and Y 2.791..4.549, placing the opening at +X. Target facing is therefore +X.",
  "reference_bone": ""
}{
"revision": 2,
"declared": true
}006query_surfacev2 → v2完成
2026-10-14 / 06:47:45.298969+08:00
{
  "object_name": "Furniture::SofaFactory_1935615__spawn_asset_3130031_",
  "point_world_m": [
    0.9,
    3.3,
    0.72
  ],
  "limit": 12,
  "radius_m": 0.18
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0.716685,
3.298722,
0.637864
],
"normal_world": [
0.912565,
0.006361,
0.408882
],
"face_index": 127877,
"distance_m": 0.20087873935699463
}
}007query_surfacev2 → v2完成
2026-10-14 / 06:47:46.381149+08:00
{
  "object_name": "Furniture::SofaFactory_1935615__spawn_asset_3130031_",
  "point_world_m": [
    0.9,
    4.05,
    0.72
  ],
  "limit": 12,
  "radius_m": 0.18
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0.716743,
4.051278,
0.63789
],
"normal_world": [
0.912565,
-0.006361,
0.408882
],
"face_index": 400,
"distance_m": 0.20081564784049988
}
}008query_surfacev2 → v2完成
2026-10-14 / 06:47:47.919609+08:00
{
  "object_name": "Human",
  "point_world_m": [
    0,
    0.04,
    0.84
  ],
  "limit": 12,
  "radius_m": 0.18
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0,
0.05604,
0.834356
],
"normal_world": [
-0.973578,
0.206546,
-0.097388
],
"face_index": 10590,
"distance_m": 0.017003720626235008
},
"vertex_samples": [
{
"vertex_index": 4241,
"point_world_m": [
0,
0.054776,
0.830765
],
"weights": [
[
"Mid",
1
],
[
"body",
1
],
[
"pelvis.L",
0.1514
],
[
"upperleg01.L",
0.0541
],
[
"pelvis.R",
0.1518
],
[
"upperleg01.R",
0.0541
],
[
"spine05",
0.5662
],
[
"spine04",
0.0224
]
]
},
{
"vertex_index": 4232,
"point_world_m": [
0,
0.060641,
0.847431
],
"weights": [
[
"Mid",
1
],
[
"body",
1
],
[
"pelvis.L",
0.1852
],
[
"upperleg01.L",
0.0568
],
[
"pelvis.R",
0.1858
],
[
"upperleg01.R",
0.0567
],
[
"spine05",
0.4708
],
[
"spine04",
0.0447
]
]
},
{
"vertex_index": 4250,
"point_world_m": [
0,
0.04494,
0.817781
],
"weights": [
[
"Mid",
1
],
[
"body",
1
],
[
"pelvis.L",
0.1177
],
[
"upperleg01.L",
0.0515
],
[
"pelvis.R",
0.1178
],
[
"upperleg01.R",
0.0515
],
[
"spine05",
0.6615
]
]
}
]
}009query_surfacev2 → v2完成
2026-10-14 / 06:47:49.459016+08:00
{
  "object_name": "Human",
  "point_world_m": [
    0.14,
    -0.02,
    0.03
  ],
  "limit": 12,
  "radius_m": 0.18
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0.160062,
-0.022054,
0.031328
],
"normal_world": [
-0.992632,
0.102886,
-0.063999
],
"face_index": 12178,
"distance_m": 0.02021062932908535
},
"vertex_samples": [
{
"vertex_index": 12904,
"point_world_m": [
0.161087,
-0.01526,
0.026346
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"foot.L",
1
]
]
},
{
"vertex_index": 12941,
"point_world_m": [
0.160878,
-0.015494,
0.036755
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"lowerleg02.L",
0.0086
],
[
"foot.L",
0.9914
]
]
},
{
"vertex_index": 12905,
"point_world_m": [
0.160984,
-0.015394,
0.016768
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"foot.L",
1
]
]
}
]
}010query_surfacev2 → v2完成
2026-10-14 / 06:47:50.984254+08:00
{
  "object_name": "Human",
  "point_world_m": [
    -0.14,
    -0.02,
    0.03
  ],
  "limit": 12,
  "radius_m": 0.18
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
-0.160062,
-0.022054,
0.031328
],
"normal_world": [
0.992632,
0.102887,
-0.063999
],
"face_index": 5453,
"distance_m": 0.020210588350892067
},
"vertex_samples": [
{
"vertex_index": 6307,
"point_world_m": [
-0.161087,
-0.015261,
0.026345
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"foot.R",
1
]
]
},
{
"vertex_index": 6344,
"point_world_m": [
-0.160878,
-0.015494,
0.036754
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"lowerleg02.R",
0.0086
],
[
"foot.R",
0.9914
]
]
},
{
"vertex_index": 6308,
"point_world_m": [
-0.160984,
-0.015394,
0.016768
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"foot.R",
1
]
]
}
]
}011query_surfacev2 → v2完成
2026-10-14 / 06:48:01.181112+08:00
{
  "object_name": "Furniture::SofaFactory_1935615__spawn_asset_3130031_",
  "point_world_m": [
    1.05,
    3.45,
    0.75
  ],
  "limit": 10,
  "radius_m": 0.22
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
1.05,
3.45,
0.502367
],
"normal_world": [
0,
0.000001,
1
],
"face_index": 5947,
"distance_m": 0.2476332187652588
}
}012query_surfacev2 → v2完成
2026-10-14 / 06:48:02.249945+08:00
{
  "object_name": "Furniture::SofaFactory_1935615__spawn_asset_3130031_",
  "point_world_m": [
    1.05,
    3.45,
    0.85
  ],
  "limit": 10,
  "radius_m": 0.22
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
1.05,
3.45,
0.502367
],
"normal_world": [
0,
0.000001,
1
],
"face_index": 5947,
"distance_m": 0.3476332426071167
}
}013query_surfacev2 → v2完成
2026-10-14 / 06:48:03.311542+08:00
{
  "object_name": "Furniture::SofaFactory_1935615__spawn_asset_3130031_",
  "point_world_m": [
    1.25,
    3.45,
    0.8
  ],
  "limit": 10,
  "radius_m": 0.22
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
1.244359,
3.45,
0.502195
],
"normal_world": [
0.018939,
0,
0.999821
],
"face_index": 6046,
"distance_m": 0.29785794019699097
}
}014query_surfacev2 → v2完成
2026-10-14 / 06:48:04.353745+08:00
{
  "object_name": "Furniture::SofaFactory_1935615__spawn_asset_3130031_",
  "point_world_m": [
    1.05,
    3.45,
    0.55
  ],
  "limit": 10,
  "radius_m": 0.22
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
1.05,
3.45,
0.502367
],
"normal_world": [
0,
0.000001,
1
],
"face_index": 5947,
"distance_m": 0.047633230686187744
},
"vertex_samples": [
{
"vertex_index": 64308,
"point_world_m": [
1.049311,
3.432462,
0.502367
],
"weights": []
},
{
"vertex_index": 8665,
"point_world_m": [
1.049311,
3.481988,
0.502367
],
"weights": []
},
{
"vertex_index": 95700,
"point_world_m": [
1.114412,
3.432462,
0.502367
],
"weights": []
}
]
}015query_surfacev2 → v2完成
2026-10-14 / 06:48:05.411778+08:00
{
  "object_name": "Furniture::SofaFactory_1935615__spawn_asset_3130031_",
  "point_world_m": [
    1.45,
    4.1,
    0.75
  ],
  "limit": 10,
  "radius_m": 0.22
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
1.396516,
4.1,
0.491915
],
"normal_world": [
0.358496,
-0.000001,
0.933531
],
"face_index": 130879,
"distance_m": 0.26356881856918335
}
}016scene_snapshotv2 → v2完成
2026-10-14 / 06:48:05.909061+08:00
{
  "bone_query": "left_knee_ik",
  "offset": 0,
  "limit": 30,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}017scene_snapshotv2 → v2完成
2026-10-14 / 06:48:06.408341+08:00
{
  "bone_query": "right_knee_ik",
  "offset": 0,
  "limit": 30,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}018scene_snapshotv2 → v2完成
2026-10-14 / 06:48:06.907508+08:00
{
  "bone_query": "left_foot_ik",
  "offset": 0,
  "limit": 30,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}019scene_snapshotv2 → v2完成
2026-10-14 / 06:48:07.410070+08:00
{
  "bone_query": "right_foot_ik",
  "offset": 0,
  "limit": 30,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}020scene_snapshotv2 → v2完成
2026-10-14 / 06:48:07.911851+08:00
{
  "bone_query": "root",
  "offset": 0,
  "limit": 30,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}021scene_snapshotv2 → v2完成
2026-10-14 / 06:48:30.401488+08:00
{
  "bone_query": "upperleg01.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}022scene_snapshotv2 → v2完成
2026-10-14 / 06:48:30.909817+08:00
{
  "bone_query": "upperleg02.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}023scene_snapshotv2 → v2完成
2026-10-14 / 06:48:31.414120+08:00
{
  "bone_query": "lowerleg01.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}024scene_snapshotv2 → v2完成
2026-10-14 / 06:48:31.920375+08:00
{
  "bone_query": "lowerleg02.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}025scene_snapshotv2 → v2完成
2026-10-14 / 06:48:32.420042+08:00
{
  "bone_query": "foot.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}026scene_snapshotv2 → v2完成
2026-10-14 / 06:48:32.931329+08:00
{
  "bone_query": "upperleg01.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}027scene_snapshotv2 → v2完成
2026-10-14 / 06:48:33.435393+08:00
{
  "bone_query": "upperleg02.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}028scene_snapshotv2 → v2完成
2026-10-14 / 06:48:33.941765+08:00
{
  "bone_query": "lowerleg01.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}029scene_snapshotv2 → v2完成
2026-10-14 / 06:48:34.441322+08:00
{
  "bone_query": "lowerleg02.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}030scene_snapshotv2 → v2完成
2026-10-14 / 06:48:34.941087+08:00
{
  "bone_query": "foot.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}031scene_snapshotv2 → v2完成
2026-10-14 / 06:48:35.445937+08:00
{
  "bone_query": "spine03",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}032scene_snapshotv2 → v2完成
2026-10-14 / 06:48:35.950218+08:00
{
  "bone_query": "spine04",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}033scene_snapshotv2 → v2完成
2026-10-14 / 06:48:36.452880+08:00
{
  "bone_query": "spine05",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}034scene_snapshotv2 → v2完成
2026-10-14 / 06:48:36.952647+08:00
{
  "bone_query": "neck01",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}035scene_snapshotv2 → v2完成
2026-10-14 / 06:48:37.455915+08:00
{
  "bone_query": "head",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 2
}036query_surfacev2 → v2完成
2026-10-14 / 06:48:53.231705+08:00
{
  "object_name": "Human",
  "point_world_m": [
    0,
    0.08,
    0.78
  ],
  "limit": 12,
  "radius_m": 0.1
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0.01629,
0.060458,
0.806255
],
"normal_world": [
-0.49002,
0.500684,
-0.713579
],
"face_index": 10607,
"distance_m": 0.036559026688337326
},
"vertex_samples": [
{
"vertex_index": 10880,
"point_world_m": [
0.020376,
0.062068,
0.804918
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"pelvis.L",
0.3052
],
[
"upperleg01.L",
0.2931
],
[
"spine05",
0.4017
]
]
},
{
"vertex_index": 4247,
"point_world_m": [
-0.020375,
0.062068,
0.804918
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"pelvis.R",
0.3442
],
[
"upperleg01.R",
0.2768
],
[
"spine05",
0.379
]
]
},
{
"vertex_index": 10881,
"point_world_m": [
0.010561,
0.058201,
0.808129
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"pelvis.L",
0.3166
],
[
"upperleg01.L",
0.2361
],
[
"spine05",
0.4473
]
]
}
]
}037query_surfacev2 → v2完成
2026-10-14 / 06:48:54.746580+08:00
{
  "object_name": "Human",
  "point_world_m": [
    0,
    0.04,
    0.78
  ],
  "limit": 12,
  "radius_m": 0.1
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0.012465,
0.033643,
0.792073
],
"normal_world": [
-0.719817,
0.312523,
-0.619833
],
"face_index": 10614,
"distance_m": 0.018480589613318443
},
"vertex_samples": [
{
"vertex_index": 4265,
"point_world_m": [
-0.012318,
0.028854,
0.789703
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"pelvis.R",
0.1707
],
[
"upperleg01.R",
0.2271
],
[
"spine05",
0.6022
]
]
},
{
"vertex_index": 10896,
"point_world_m": [
0.01232,
0.028854,
0.789701
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"pelvis.L",
0.181
],
[
"upperleg01.L",
0.2631
],
[
"spine05",
0.5559
]
]
},
{
"vertex_index": 10897,
"point_world_m": [
0.007554,
0.026936,
0.79463
],
"weights": [
[
"Mid",
1
],
[
"body",
1
],
[
"pelvis.L",
0.1303
],
[
"upperleg01.L",
0.1222
],
[
"spine05",
0.7475
]
]
}
]
}038query_surfacev2 → v2完成
2026-10-14 / 06:48:56.290721+08:00
{
  "object_name": "Human",
  "point_world_m": [
    0.05,
    0.05,
    0.78
  ],
  "limit": 12,
  "radius_m": 0.1
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0.049541,
0.050703,
0.779099
],
"normal_world": [
-0.386442,
0.579829,
-0.717259
],
"face_index": 10604,
"distance_m": 0.0012319793459028006
},
"vertex_samples": [
{
"vertex_index": 10886,
"point_world_m": [
0.053978,
0.045681,
0.77292
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"pelvis.L",
0.2967
],
[
"upperleg01.L",
0.5827
],
[
"spine05",
0.1206
]
]
},
{
"vertex_index": 10887,
"point_world_m": [
0.030658,
0.045946,
0.784999
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"pelvis.L",
0.2495
],
[
"upperleg01.L",
0.3837
],
[
"spine05",
0.3668
]
]
},
{
"vertex_index": 10878,
"point_world_m": [
0.053845,
0.07052,
0.792373
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"pelvis.L",
0.4227
],
[
"upperleg01.L",
0.5084
],
[
"spine05",
0.0689
]
]
}
]
}039query_surfacev2 → v2完成
2026-10-14 / 06:48:57.801997+08:00
{
  "object_name": "Human",
  "point_world_m": [
    -0.05,
    0.05,
    0.78
  ],
  "limit": 12,
  "radius_m": 0.1
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
-0.049541,
0.050703,
0.779099
],
"normal_world": [
0.386437,
0.579833,
-0.717259
],
"face_index": 3950,
"distance_m": 0.0012320526875555515
},
"vertex_samples": [
{
"vertex_index": 4254,
"point_world_m": [
-0.053978,
0.045681,
0.77292
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"pelvis.R",
0.2969
],
[
"upperleg01.R",
0.5825
],
[
"spine05",
0.1206
]
]
},
{
"vertex_index": 4255,
"point_world_m": [
-0.03066,
0.045946,
0.784998
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"pelvis.R",
0.2182
],
[
"upperleg01.R",
0.415
],
[
"spine05",
0.3668
]
]
},
{
"vertex_index": 4245,
"point_world_m": [
-0.053845,
0.07052,
0.792372
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"pelvis.R",
0.4241
],
[
"upperleg01.R",
0.507
],
[
"spine05",
0.0689
]
]
}
]
}040query_surfacev2 → v2完成
2026-10-14 / 06:48:59.355937+08:00
{
  "object_name": "Human",
  "point_world_m": [
    0,
    0.08,
    0.8
  ],
  "limit": 12,
  "radius_m": 0.1
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0.011318,
0.064843,
0.814487
],
"normal_world": [
-0.465083,
0.635702,
-0.616101
],
"face_index": 10602,
"distance_m": 0.023826725780963898
},
"vertex_samples": [
{
"vertex_index": 10881,
"point_world_m": [
0.010561,
0.058201,
0.808129
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"pelvis.L",
0.3166
],
[
"upperleg01.L",
0.2361
],
[
"spine05",
0.4473
]
]
},
{
"vertex_index": 4248,
"point_world_m": [
-0.010561,
0.058201,
0.808129
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"pelvis.R",
0.315
],
[
"upperleg01.R",
0.2341
],
[
"spine05",
0.4391
],
[
"spine04",
0.0118
]
]
},
{
"vertex_index": 4239,
"point_world_m": [
-0.010003,
0.071531,
0.822513
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"pelvis.R",
0.4068
],
[
"upperleg01.R",
0.2076
],
[
"spine05",
0.353
],
[
"spine04",
0.0326
]
]
}
]
}041query_surfacev2 → v2完成
2026-10-14 / 06:49:00.875858+08:00
{
  "object_name": "Human",
  "point_world_m": [
    0,
    0.04,
    0.8
  ],
  "limit": 12,
  "radius_m": 0.1
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
-0.004384,
0.037852,
0.803207
],
"normal_world": [
0.681836,
0.359885,
-0.636854
],
"face_index": 3961,
"distance_m": 0.005841420032083988
},
"vertex_samples": [
{
"vertex_index": 4258,
"point_world_m": [
-0.00716,
0.042788,
0.802719
],
"weights": [
[
"Mid",
1
],
[
"body",
1
],
[
"pelvis.R",
0.1333
],
[
"upperleg01.R",
0.0957
],
[
"spine05",
0.771
]
]
},
{
"vertex_index": 10890,
"point_world_m": [
0.00716,
0.042788,
0.802719
],
"weights": [
[
"Mid",
1
],
[
"body",
1
],
[
"pelvis.L",
0.1333
],
[
"upperleg01.L",
0.0957
],
[
"spine05",
0.771
]
]
},
{
"vertex_index": 4259,
"point_world_m": [
0,
0.034835,
0.807181
],
"weights": [
[
"Mid",
1
],
[
"body",
1
],
[
"pelvis.L",
0.0666
],
[
"upperleg01.L",
0.0479
],
[
"pelvis.R",
0.0666
],
[
"upperleg01.R",
0.0479
],
[
"spine05",
0.771
]
]
}
]
}042query_surfacev2 → v2完成
2026-10-14 / 06:49:39.002588+08:00
{
  "object_name": "Human",
  "point_world_m": [
    0.16,
    -0.08,
    0.015
  ],
  "limit": 40,
  "radius_m": 0.1
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
0.161566,
-0.080173,
0.016635
],
"normal_world": [
-0.753333,
0.104989,
-0.649205
],
"face_index": 12551,
"distance_m": 0.0022706452291458845
},
"vertex_samples": [
{
"vertex_index": 12890,
"point_world_m": [
0.163595,
-0.08879,
0.013777
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"foot.L",
1
]
]
},
{
"vertex_index": 12859,
"point_world_m": [
0.159354,
-0.070915,
0.021588
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"foot.L",
1
]
]
},
{
"vertex_index": 12856,
"point_world_m": [
0.15784,
-0.09119,
0.019037
],
"weights": [
[
"Left",
1
],
[
"body",
1
],
[
"foot.L",
1
]
]
}
]
}043query_surfacev2 → v2完成
2026-10-14 / 06:49:40.546241+08:00
{
  "object_name": "Human",
  "point_world_m": [
    -0.16,
    -0.08,
    0.015
  ],
  "limit": 40,
  "radius_m": 0.1
}{
"revision": 2,
"nearest_surface": {
"point_world_m": [
-0.161566,
-0.080173,
0.016635
],
"normal_world": [
0.753332,
0.104989,
-0.649205
],
"face_index": 5824,
"distance_m": 0.002270479453727603
},
"vertex_samples": [
{
"vertex_index": 6293,
"point_world_m": [
-0.163595,
-0.088791,
0.013777
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"foot.R",
1
]
]
},
{
"vertex_index": 6262,
"point_world_m": [
-0.159354,
-0.070915,
0.021588
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"foot.R",
1
]
]
},
{
"vertex_index": 6259,
"point_world_m": [
-0.15784,
-0.09119,
0.019037
],
"weights": [
[
"Right",
1
],
[
"body",
1
],
[
"foot.R",
1
]
]
}
]
}044declare_interactionv2 → v3完成
2026-10-14 / 06:49:52.662115+08:00
{
  "intent": "Static seated pose on the regular (non-chaise) cushion of the sofa, facing its +X opening. The lower glute skin bears on the seat; both plantar forefeet/soles support on the virtual floor; arms remain relaxed without furniture contact.",
  "contacts": [
    {
      "label": "Lower glute underside skin patch",
      "body_mesh": "Human",
      "vertex_indices": [
        10894,
        4263,
        10886
      ],
      "target_object": "Furniture::SofaFactory_1935615__spawn_asset_3130031_",
      "purpose": "support"
    },
    {
      "label": "Left plantar sole support patch",
      "body_mesh": "Human",
      "vertex_indices": [
        12896,
        12889,
        12893
      ],
      "target_object": "__floor__",
      "purpose": "support"
    },
    {
      "label": "Right plantar sole support patch",
      "body_mesh": "Human",
      "vertex_indices": [
        6299,
        6292,
        6296
      ],
      "target_object": "__floor__",
      "purpose": "support"
    }
  ]
}{
"revision": 3,
"declared": true
}045observe_posev3 → v3完成
2026-10-14 / 06:50:05.699869+08:00
{}{
"revision": 3
}046edit_scenev3 → v4完成
2026-10-14 / 06:52:08.494648+08:00
{
  "code": "import bpy, math\nfrom mathutils import Matrix, Vector\nrig = bpy.data.objects[\"Human.rig\"]\nroot = rig.pose.bones[\"root\"]\nturn = Matrix.Rotation(math.radians(90.0), 4, \"Z\")\nturn3 = turn.to_3x3()\npelvis_target = Vector((1.085, 3.300, 0.625))\nhead_tail = root.tail - root.head\nnew_root = turn @ root.matrix.copy()\nnew_root.translation = pelvis_target - turn3 @ head_tail\nroot.matrix = new_root\nbpy.context.view_layer.update()\n\n# Each knee target drives its two-bone thigh chain.\nfor name, point in [\n    (\"left_knee_ik\", (1.400, 3.370, 0.460)),\n    (\"right_knee_ik\", (1.400, 3.230, 0.460)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\n\n# Foot targets place the ankles near floor level and turn each foot toward +X.\nfor name, point in [\n    (\"left_foot_ik\", (1.440, 3.370, 0.069)),\n    (\"right_foot_ik\", (1.440, 3.230, 0.069)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = turn @ ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\nbpy.context.view_layer.update()\n",
  "reason": "Rotate the whole skeleton into the sofa's measured +X opening, seat the lower glute patch above the selected regular cushion, and bend both legs through the active knee/foot IK controllers so the soles reach the floor."
}{
"revision": 4,
"edited": true,
"geometry": {
"accepted": false,
"reasons": [
"declared_facing_not_met",
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 4047.7319341542698,
"new_self_pairs": 94
}
}047observe_posev4 → v4完成
2026-10-14 / 06:52:16.803043+08:00
{}{
"revision": 4
}048declare_orientationv4 → v5完成
2026-10-14 / 06:52:42.948744+08:00
{
  "body_forward_local": [
    0,
    1,
    0
  ],
  "furniture_opening_world": [
    1,
    0,
    0
  ],
  "target_forward_world": [
    1,
    0,
    0
  ],
  "evidence": "The revision-4 world_minus_Y view shows the character's face in profile looking screen-right, which is world +X. The world_plus_X view shows the face and chest, confirming +X facing. The top view shows the pelvis on the regular left seat cushion, feet extending into the clear +X opening, with the chaise on the adjacent cushion. This declaration uses the posed root-bone frame: its local +Y axis now maps to the visually confirmed world +X forward direction. The sofa opening remains +X, as shown by its back edge at -X and seat/chaise geometry extending +X.",
  "reference_bone": "root"
}{
"revision": 5,
"declared": true
}049evaluate_posev5 → v5完成
2026-10-14 / 06:54:24.560661+08:00
{}{
"revision": 5,
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"geometry": {
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 4047.7319341542698,
"new_self_pairs": 94
}
}050evaluate_posev5 → v5完成
2026-10-14 / 06:56:07.466732+08:00
{}{
"revision": 5,
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"geometry": {
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 4047.7319341542698,
"new_self_pairs": 94
}
}051scene_snapshotv5 → v5完成
2026-10-14 / 06:56:49.451928+08:00
{
  "bone_query": "shoulder01.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}052scene_snapshotv5 → v5完成
2026-10-14 / 06:56:49.944881+08:00
{
  "bone_query": "upperarm01.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}053scene_snapshotv5 → v5完成
2026-10-14 / 06:56:50.453250+08:00
{
  "bone_query": "upperarm02.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}054scene_snapshotv5 → v5完成
2026-10-14 / 06:56:50.947750+08:00
{
  "bone_query": "lowerarm01.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}055scene_snapshotv5 → v5完成
2026-10-14 / 06:56:51.464312+08:00
{
  "bone_query": "lowerarm02.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}056scene_snapshotv5 → v5完成
2026-10-14 / 06:56:51.968291+08:00
{
  "bone_query": "wrist.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}057scene_snapshotv5 → v5完成
2026-10-14 / 06:56:52.478466+08:00
{
  "bone_query": "shoulder01.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}058scene_snapshotv5 → v5完成
2026-10-14 / 06:56:52.979627+08:00
{
  "bone_query": "upperarm01.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}059scene_snapshotv5 → v5完成
2026-10-14 / 06:56:53.483253+08:00
{
  "bone_query": "upperarm02.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}060scene_snapshotv5 → v5完成
2026-10-14 / 06:56:53.992068+08:00
{
  "bone_query": "lowerarm01.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}061scene_snapshotv5 → v5完成
2026-10-14 / 06:56:54.488350+08:00
{
  "bone_query": "lowerarm02.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}062scene_snapshotv5 → v5完成
2026-10-14 / 06:56:54.996327+08:00
{
  "bone_query": "wrist.R",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}063scene_snapshotv5 → v5完成
2026-10-14 / 06:57:22.175530+08:00
{
  "bone_query": "left_elbow_ik",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}064scene_snapshotv5 → v5完成
2026-10-14 / 06:57:22.686229+08:00
{
  "bone_query": "right_elbow_ik",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}065scene_snapshotv5 → v5完成
2026-10-14 / 06:57:23.190132+08:00
{
  "bone_query": "left_hand_ik",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}066scene_snapshotv5 → v5完成
2026-10-14 / 06:57:23.688613+08:00
{
  "bone_query": "right_hand_ik",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}067scene_snapshotv5 → v5完成
2026-10-14 / 06:57:24.195199+08:00
{
  "bone_query": "upperleg01.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}068scene_snapshotv5 → v5完成
2026-10-14 / 06:57:24.698148+08:00
{
  "bone_query": "pelvis.L",
  "offset": 0,
  "limit": 5,
  "detailed": true
}{
"rig": "Human.rig",
"bones_total": 1,
"next_offset": null,
"revision": 5
}069observe_posev5 → v5完成
2026-10-14 / 06:57:34.452374+08:00
{}{
"revision": 5
}070edit_scenev5 → v6完成
2026-10-14 / 06:59:26.739926+08:00
{
  "code": "import bpy\nfrom mathutils import Vector\nrig = bpy.data.objects[\"Human.rig\"]\nroot = rig.pose.bones[\"root\"]\nroot.matrix.translation = root.matrix.translation + Vector((0.150, 0.0, -0.026))\nbpy.context.view_layer.update()\n\n# Keep the knees spaced with the hip width and move the shins just beyond the seat edge.\nfor name, point in [\n    (\"left_knee_ik\", (1.550, 3.450, 0.460)),\n    (\"right_knee_ik\", (1.550, 3.150, 0.460)),\n    (\"left_foot_ik\", (1.590, 3.410, 0.069)),\n    (\"right_foot_ik\", (1.590, 3.190, 0.069)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\nbpy.context.view_layer.update()\n\n# Bring elbows and hands inward from the sofa's side arms to a relaxed lap position.\nfor name, point in [\n    (\"left_elbow_ik\", (1.320, 3.450, 0.900)),\n    (\"right_elbow_ik\", (1.320, 3.150, 0.900)),\n    (\"left_hand_ik\", (1.380, 3.420, 0.630)),\n    (\"right_hand_ik\", (1.380, 3.180, 0.630)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\n    bpy.context.view_layer.update()\n",
  "reason": "Refine the seated contact at the cushion front edge, separate thighs to reduce groin crossing, keep shins in the clear +X opening, and bring both hands onto the lap away from the sofa arm panels."
}{
"revision": 6,
"edited": true,
"geometry": {
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 168.8780465006921,
"new_self_pairs": 490
}
}071observe_posev6 → v6完成
2026-10-14 / 06:59:39.413947+08:00
{}{
"revision": 6
}072evaluate_posev6 → v6完成
2026-10-14 / 07:01:28.797625+08:00
{}{
"revision": 6,
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"geometry": {
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 168.8780465006921,
"new_self_pairs": 490
}
}073observe_posev6 → v6完成
2026-10-14 / 07:02:08.199935+08:00
{}{
"revision": 6
}074edit_scenev6 → v7完成
2026-10-14 / 07:04:02.065178+08:00
{
  "code": "import bpy\nfrom mathutils import Vector\nrig = bpy.data.objects[\"Human.rig\"]\nroot = rig.pose.bones[\"root\"]\nroot.matrix.translation = root.matrix.translation + Vector((0.050, 0.0, 0.0))\nbpy.context.view_layer.update()\n\n# Move both thighs beyond the cushion edge while keeping the shins near vertical.\nfor name, point in [\n    (\"left_knee_ik\", (1.650, 3.450, 0.470)),\n    (\"right_knee_ik\", (1.650, 3.150, 0.470)),\n    (\"left_foot_ik\", (1.670, 3.410, 0.069)),\n    (\"right_foot_ik\", (1.670, 3.190, 0.069)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\nbpy.context.view_layer.update()\n\n# Let the upper arms stay outside the torso, with hands resting over their respective thighs.\nfor name, point in [\n    (\"left_elbow_ik\", (1.340, 3.560, 0.920)),\n    (\"right_elbow_ik\", (1.340, 3.040, 0.920)),\n    (\"left_hand_ik\", (1.490, 3.460, 0.550)),\n    (\"right_hand_ik\", (1.490, 3.140, 0.550)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\n    bpy.context.view_layer.update()\n",
  "reason": "Clear remaining thigh contact with the cushion's front edge, keep the lower legs downward to the floor, and move elbows outside the torso while settling hands on the thighs to reduce arm/torso self-crossings."
}{
"revision": 7,
"edited": true,
"geometry": {
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 22.75286580708191,
"new_self_pairs": 282
}
}075observe_posev7 → v7完成
2026-10-14 / 07:04:21.414957+08:00
{}{
"revision": 7
}076evaluate_posev7 → v7完成
2026-10-14 / 07:06:07.407496+08:00
{}{
"revision": 7,
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"geometry": {
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 22.75286580708191,
"new_self_pairs": 282
}
}077edit_scenev7 → v8完成
2026-10-14 / 07:08:30.395070+08:00
{
  "code": "import bpy\nfrom mathutils import Vector\nrig = bpy.data.objects[\"Human.rig\"]\nroot = rig.pose.bones[\"root\"]\nroot.matrix.translation = root.matrix.translation + Vector((0.030, 0.0, 0.0))\nbpy.context.view_layer.update()\n\n# Keep the thigh line just beyond the cushion edge and preserve the floor-reaching shins.\nfor name, point in [\n    (\"left_knee_ik\", (1.680, 3.450, 0.470)),\n    (\"right_knee_ik\", (1.680, 3.150, 0.470)),\n    (\"left_foot_ik\", (1.700, 3.410, 0.069)),\n    (\"right_foot_ik\", (1.700, 3.190, 0.069)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\nbpy.context.view_layer.update()\n\n# Give the upper arms a little more clearance from the torso and leave the hands above each thigh.\nfor name, point in [\n    (\"left_elbow_ik\", (1.340, 3.610, 0.970)),\n    (\"right_elbow_ik\", (1.340, 2.990, 0.970)),\n    (\"left_hand_ik\", (1.450, 3.460, 0.620)),\n    (\"right_hand_ik\", (1.450, 3.140, 0.620)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\n    bpy.context.view_layer.update()\n",
  "reason": "Fine-tune the front-edge seated position to remove the remaining thigh/cushion overlap and abduct both upper arms slightly for shoulder clearance while keeping the hands on the lap."
}{
"revision": 8,
"edited": true,
"geometry": {
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 5.494077048482546,
"new_self_pairs": 202
}
}078observe_posev8 → v8完成
2026-10-14 / 07:08:39.318623+08:00
{}{
"revision": 8
}079evaluate_posev8 → v8完成
2026-10-14 / 07:10:26.353095+08:00
{}{
"revision": 8,
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"geometry": {
"accepted": false,
"reasons": [
"body_furniture_collision",
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 5.494077048482546,
"new_self_pairs": 202
}
}080edit_scenev8 → v9完成
2026-10-14 / 07:12:44.431581+08:00
{
  "code": "import bpy\nfrom mathutils import Vector\nrig = bpy.data.objects[\"Human.rig\"]\nroot = rig.pose.bones[\"root\"]\nroot.matrix.translation = root.matrix.translation + Vector((0.0, 0.0, 0.012))\nbpy.context.view_layer.update()\n\n# Hang the hands just outside the thighs rather than letting fingers pass through the legs.\nfor name, point in [\n    (\"left_hand_ik\", (1.450, 3.630, 0.620)),\n    (\"right_hand_ik\", (1.450, 2.970, 0.620)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\n    bpy.context.view_layer.update()\n",
  "reason": "Lift the pelvis slightly to remove the remaining few-micrometre-scale thigh/cushion overlap while keeping the glute patch close to the seat, and place hands just outside the thighs to avoid finger/leg crossings."
}{
"revision": 9,
"edited": true,
"geometry": {
"accepted": false,
"reasons": [
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 0,
"new_self_pairs": 48
}
}081observe_posev9 → v9完成
2026-10-14 / 07:12:54.281482+08:00
{}{
"revision": 9
}082evaluate_posev9 → v9完成
2026-10-14 / 07:14:39.912689+08:00
{}{
"revision": 9,
"accepted": false,
"reasons": [
"new_or_worsened_body_self_crossing"
],
"geometry": {
"accepted": false,
"reasons": [
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 0,
"new_self_pairs": 48
}
}083edit_scenev9 → v10完成
2026-10-14 / 07:16:52.828890+08:00
{
  "code": "import bpy\nfrom mathutils import Vector\nrig = bpy.data.objects[\"Human.rig\"]\n# Widen the thighs at the hips, with a modestly wider stance for both soles.\nfor name, point in [\n    (\"left_knee_ik\", (1.655, 3.515, 0.460)),\n    (\"right_knee_ik\", (1.655, 3.085, 0.460)),\n    (\"left_foot_ik\", (1.690, 3.430, 0.069)),\n    (\"right_foot_ik\", (1.690, 3.170, 0.069)),\n]:\n    ctrl = rig.pose.bones[name]\n    m = ctrl.matrix.copy()\n    m.translation = Vector(point)\n    ctrl.matrix = m\n    bpy.context.view_layer.update()\n",
  "reason": "Move the knees slightly outward at the hip line to reduce the remaining thigh/pelvis self-crossing while preserving achievable leg lengths and close floor-supported feet."
}{
"revision": 10,
"edited": true,
"geometry": {
"accepted": false,
"reasons": [
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 0,
"new_self_pairs": 6
}
}084observe_posev10 → v10完成
2026-10-14 / 07:17:03.890861+08:00
{}{
"revision": 10
}085evaluate_posev10 → v10完成
2026-10-14 / 07:18:42.010012+08:00
{}{
"revision": 10,
"accepted": false,
"reasons": [
"new_or_worsened_body_self_crossing"
],
"geometry": {
"accepted": false,
"reasons": [
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 0,
"new_self_pairs": 6
}
}086scene_snapshotv10 → v10完成
2026-10-14 / 07:18:42.475583+08:00
{
  "bone_query": "",
  "offset": 0,
  "limit": 1,
  "detailed": false
}{
"rig": "Human.rig",
"bones_total": 160,
"next_offset": 1,
"revision": 10
}087finish_posev10 → v10完成
2026-10-14 / 07:20:29.674277+08:00
{
  "success": false,
  "intent_satisfied": true,
  "visual_review": "Reviewed the fresh revision-10 world_minus_Y, world_plus_X, and world_plus_Z views. The character is seated on the regular sofa cushion, facing the measured +X opening; the pelvis is close to the cushion top, the knees are bent, both feet reach the virtual floor, and the arms rest relaxed beside the thighs. The front and top views confirm the character is not standing or facing away from the opening. This is visually a seated interaction, but geometry acceptance is false because six new self-crossing pairs remain.",
  "remaining_issues": [
    "Final evaluate_pose rejected the draft for new_or_worsened_body_self_crossing: 6 new pairs remain (38 current versus 32 initial).",
    "Two crossings are at the lower torso/hip-to-thigh junctions: evaluated faces 4033/4036 on the right and 10710/10721 on the left.",
    "Four crossings are at the right knee/thigh-to-shin junction (face 4215 against 4247, 4258, 4268, and 4273).",
    "The final evaluation found zero body/furniture overlap; glute and both sole support patches passed, and the declared facing error is 0 degrees."
  ]
}{
"revision": 10,
"success": false,
"status": "draft",
"fresh_evidence": true,
"geometry": {
"accepted": false,
"reasons": [
"new_or_worsened_body_self_crossing"
],
"overlap_cm3": 0,
"new_self_pairs": 6
}
}